|
Ruopeng Huang I am a Ph.D. student in CEE at UCLA, advised by Prof. Chen Tang in the Trustworthy Autonomous Mobility Systems (TAMS) Lab. Before joining UCLA, I was a Master's student in Computer Science (Intelligent Robotics) at the University of Southern California, where I conducted research in Prof. Erdem Biyik's LiraLab. I was also a visiting student at the TASL at UC Riverside, working with Prof. Jiachen Li, and previously conducted research at USC's RRoS Lab, advised by Prof. S. K. Gupta. I received my bachelor's degree in Computer Science and Technology from Beijing University of Posts and Telecommunications. My research interests include robotic manipulation, robot perception, and robot learning, with an emphasis on building robust robotic systems for real-world deployment. |
|
Research |
|
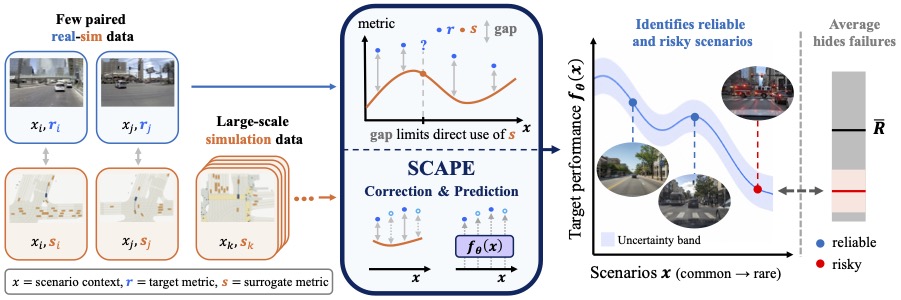
SCAPE: Scenario-Conditioned Simulation-Augmented Policy Evaluation
Dijie Zhu, Seunghun Oh, Ruopeng Huang, Zhiyu Huang, Jiaqi Ma, Chen Tang Conference on Robot Learning (CoRL), 2026 paper |
|
SyncTwin: Fast Digital Twin Construction and Synchronization for Safe Robotic Manipulation
Ruopeng Huang, Boyu Yang, Wenlong Gui, Jeremy Morgan, Erdem Biyik, Jiachen Li paper / project page We present SyncTwin, a fast digital twin construction and synchronization framework for safe robotic grasping in dynamic and partially observed environments. |
|
|
Robotic Compliant Object Prying Using Diffusion Policy Guided by Vision and Force Observations
Jeon Ho Kang, Sagar Joshi, Ruopeng Huang, Satyandra K. Gupta IEEE Robotics and Automation Letters (RA-L), 2025 (Accepted) paper / project page / code This work presents a diffusion-policy-based approach for compliant object prying, integrating vision and force observations for robust contact-rich manipulation. |
|
|
Energy-Aware Planning for Legged Robots Performing Logistics Tasks in Agriculture Applications
Shengqiang Chen, Yiyu Chen, Ruopeng Huang, Quan Nguyen, Satyandra K. Gupta ASME Letters in Robotics (L-ROB), 2026 (Accepted) paper We study energy-aware motion planning for legged robots in agricultural logistics scenarios, balancing task efficiency and energy consumption in wild environments. |
Work Experience
|


Course Projects
|
Service & SkillsService
Skills
|
Hardware Experience
|
|
Webpage inspired by Jon Barron |